In brief

Compare drum-handling applications using the same drum and transfer information. Repeatable production needs representative evidence for arrival, picking, transfer and the required handover. A retrofit or flexible cell also needs its existing interfaces, drum changes, operator access and recovery cases resolved. Map the whole route before judging a robot or handling concept.

Start with the drum and process brief and transfer-to-recovery process. Empty and filled weights, permitted grip points and orientation requirements remain application-specific inputs, not assumed robot capabilities.

On the production floor

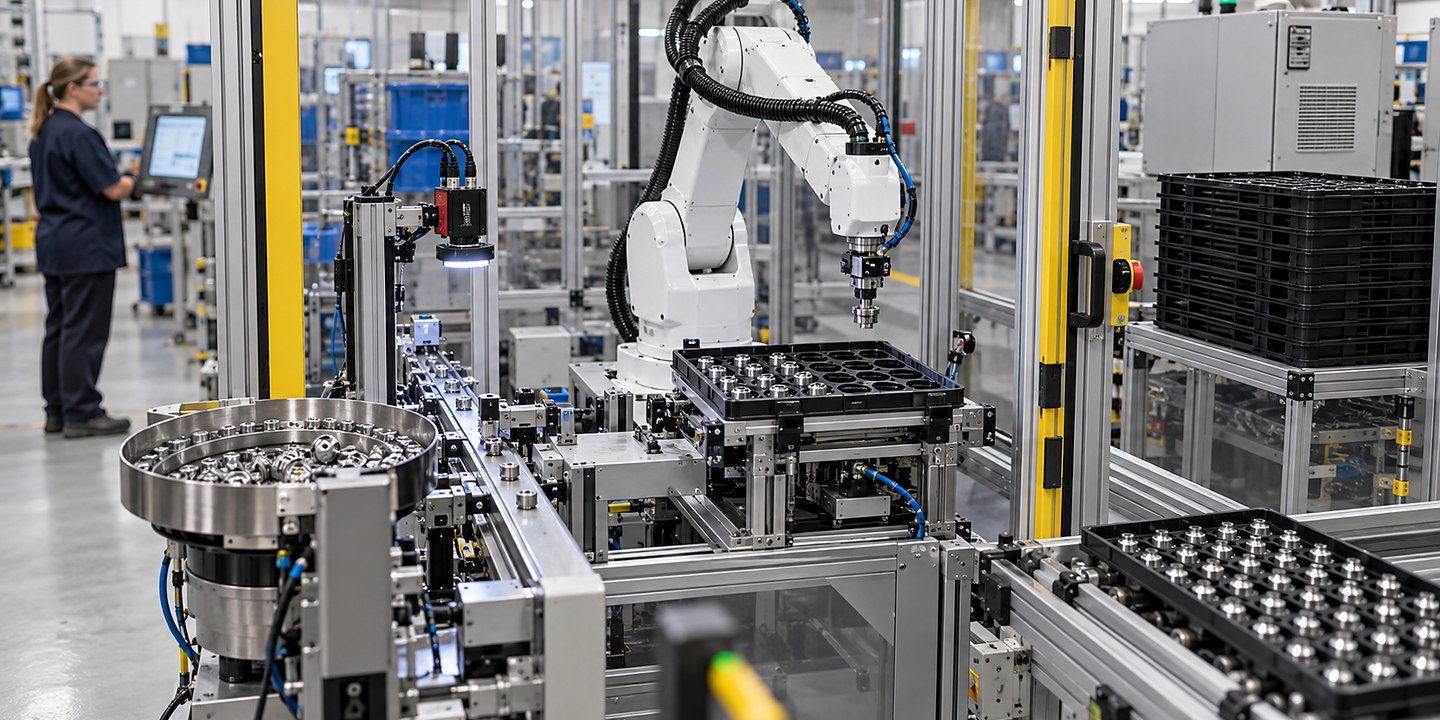
Match the solution to your product, part and operating needs — Drum Handling Robots

Plan drum handling robots around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. Use the application examples to compare repeatable production using robotic drum handling and transfer with retrofit or flexible cells involving robotic drum handling and transfer.

Discuss your application
Application 1

Repeatable Production Using Robotic Drum Handling and Transfer

Provide the drum range, empty and filled weights, grip points and the regular arrival pattern. Map every transfer, pallet pattern and orientation requirement. Use representative drums to assess accepted transfer and handover through the intended production sequence, including an incomplete pick and recovery.

Explore this application
Application 2

Retrofit or Flexible Cells Involving Robotic Drum Handling and Transfer

Record the existing arrival and destination interfaces and the drum variants that need changeover. Review tooling, sensing and the complete transfer route alongside operator access and recovery. Identify what a focused feasibility trial must resolve before defining the wider cell modification and safeguarding scope.

Explore this application
Choose the right route

Four questions that can change the recommended approach

What arrives?

Provide representative drums, empty and filled weights, dimensions and permitted grip points. Identify closures, required orientation and the intended drum range before comparing a handling concept. Record the actual arrival presentation and pallet pattern for each drum variant.

What must happen?

Map each pick, transfer and destination, including closure and orientation requirements. Define an accepted handover and the complete cycle required by the surrounding process.

What surrounds it?

Record neighbouring processes, tooling and sensing interfaces, space, services and operator tasks. Review access, recovery, changeover and complete cell safeguarding as part of the application assessment.

What result do you need?

Agree the drum range, transfer route, orientation, cycle and recovery scenarios to be demonstrated. Retain representative-drum observations, accepted transfer results and unresolved interface or safeguarding actions for review.

ApproachOften suitable whenWatch for
Drum Handling RobotsYou need a dedicated solution for a clearly defined duty, product or part range and line interface.Cycle time depends on the complete process rather than robot speed alone.
Purpose-Built Mechanical Automation for a Stable, Very High-Volume TaskInclude this existing alternative where the actual drum range and transfer task are sufficiently stable to justify assessment.Compare representative drum handling, the complete cycle, interfaces and recovery against the same agreed acceptance scope; the category name does not establish suitability.
Operator-Assisted Fixtures where Flexibility or Business Case Does Not Support a Robot CellInclude operator-assisted arrangements in the comparison when the drum mix, required flexibility or business case calls for that review.Assess the actual handling tasks, operator access and required transfer result under a competent application assessment; compare the full duty rather than robot speed alone.